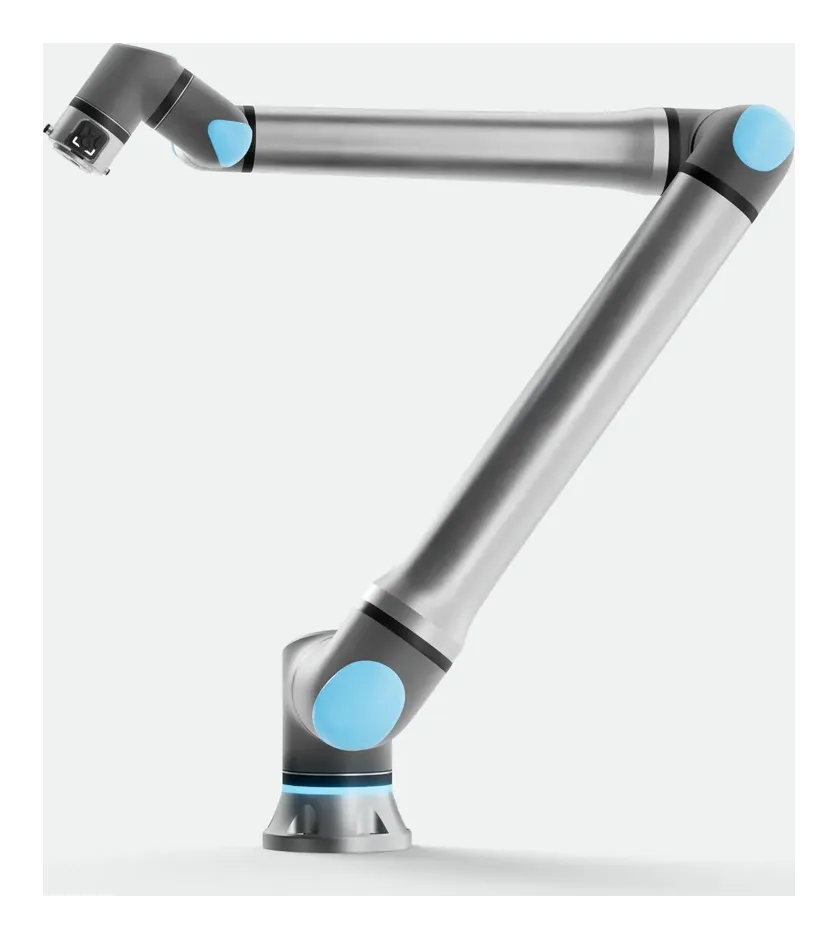
All robots
Universal Robots UR10G-1750

Photo © Universal Robots · product page

Universal Robots UR10G-1750

Collaborative arm
Payload
10 kg
Reach
1,750 mm
Repeatability
0.08 mm
Degrees of freedom
6
Mass
47.3 kg
Max speed
5 m/sHighest of 30 in this category
  • Indoor
  • Collaborative rated
  • Emergency stop
  • Force/torque sensor
  • Enabling device

52 figures from 2 published documents on universal-robots.com, each linked to the line it came from

Specifications

Physical

Mass47.3 kgUniversal Robots
Payload10 kgUniversal Robots
Reach1,750 mmUniversal Robots
Degrees of freedom6Universal Robots
Repeatability0.08 mmUniversal Robots
Base footprint204 mmUniversal Robots
MaterialsAluminium, plastic, steelUniversal Robots
MountingAny orientationUniversal Robots

Motion

Max speed5 m/sUniversal Robots

Joints

Joint architecture2-1-3Universal Robots
J1 range360°Universal Robots
J1 max speed180°/sUniversal Robots
J2 range360°Universal Robots
J2 max speed180°/sUniversal Robots
J3 range360°Universal Robots
J3 max speed240°/sUniversal Robots
J4 range360°Universal Robots
J4 max speed300°/sUniversal Robots
J5 range360°Universal Robots
J5 max speed300°/sUniversal Robots
J6 range360°Universal Robots
J6 max speed300°/sUniversal Robots

Force sensing

Force range150 NUniversal Robots
Force precision7.5 NUniversal Robots
Force accuracy8.3 NUniversal Robots
Torque range10 NmUniversal Robots
Torque precision0.2 NmUniversal Robots
Torque accuracy0.5 NmUniversal Robots

Tool flange

Mounting flangeISO 9409-1-50-4-M6Universal Robots
Digital inputs2Universal Robots
Digital outputs2Universal Robots
Analog inputs2Universal Robots
CommunicationEthernetUniversal Robots
Supply voltage12 or 24 VdcUniversal Robots
Supply current2 A(dual pin)Universal Robots
ConnectorM8 8-pinUniversal Robots

Power

Max power615 WUniversal Robots
Power consumption350 WUniversal Robots

Environment

Max humidity≤ 90%(non-condensing)Universal Robots
Min operating temp0°CUniversal Robots
Max operating temp50°CUniversal Robots
Noise level< 55 dBUniversal Robots
Operating environmentindoorUniversal Robots

Safety

Safety functions23Universal Robots
Status indicatorLight ring at robot baseUniversal Robots
Collaborative ratedYesUniversal Robots
Safety standardsTÜV Rheinland EN ISO 13849-1, TÜV Rheinland EN ISO 10218-1, RoHS, TÜV Rheinland cTÜVus, UL 1740, KC Mark (EMC), KCs Mark (Safety)Universal Robots
Emergency stopYesUniversal Robots

Sensing

Force/torque sensorYesUniversal Robots

Software

ProgrammingPolyScope XUniversal Robots

Controller

Hardware interfacesHarting ICC20 connector (robot cable), RJ45-type Ethernet port (Teach Pendant), IEC C14 connector (power cable)Universal Robots

Teach pendant

Enabling deviceYesUniversal Robots

Every figure links to the document it came from. See one that’s wrong? Use the beside it.

Comments